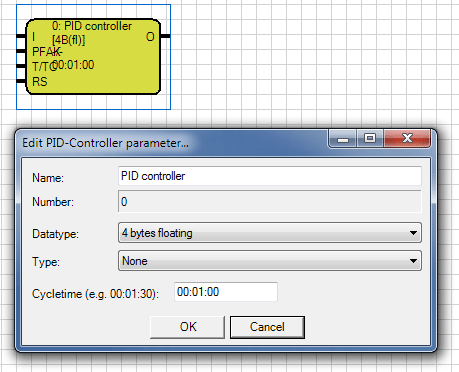
The gate is for PID control functions. It consists of a fixed proportional, an optional integral and/or differential part. The optional controller parts can be selected/deselected.
Additional integrations and differentiations functionality can be added with the parameter Type to the proportional controller.
With reset the integrator part is set to zero. To achieve a realistic calculation accuracy, the environmental assessment task cycle time should be at
least 10 times smaller than the period of the critical cut-off frequency of the control system.
Input/Output
I Input signal
PFAK Proportional factor
T/TC Time constant in seconds
RS Reset
O Output signal
The values on PFAK and at T/TC input may be changed at any time during operation.
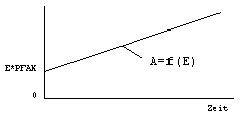
Step response
The input of each gate can be linked with an input object or an output of another function. The output
of a gate can be connected to an output, or to an input of another function. A gate output can be
connected with several gate inputs.
The inputs are marked with I, PFAK, T/TC and RS, and are left at the element.
The reset input is marked with an RS and is located left of the element. This input is invertible. This
may be made within the parameter window or by double-clicking the S-connection.
The output is characterized by an O, right top of the element. The name of the gate can be chosen freely.
Note: For the input and output are the same types of data allowed. The reset input (RS) is set to the data type Boolean (0/1).